Mail: zhihao.zhan [at] smail [dot] nju [dot] edu [dot] cn
About Me
I am currently serving as the Algorithm Team Lead at TopXGun (Nanjing)
Robotics Co., Ltd. in China, where I lead a small team focusing on SLAM, Perception, 3D Reconstruction,
and Motion Planning for UAV autopilot systems.
Previously, I received an M.Sc. in Multimedia Information Technology from the City University of Hong Kong, supervised by Prof. Ho
Man Chan.
My research interests lie in Spatial Intelligence and Field Robotics, particularly in the following
areas:
Multi-Sensor Fusion SLAM and Structure-from-Motion (SfM), aiming to achieve robust localization, mapping,
and 3D reconstruction using LiDAR, camera, radar, IMU, and GNSS measurements.
Embodied Spatial AI, emphasizing 3D scene understanding, neural spatial representation, and
geometry-aware spatial reasoning for robotic perception and interaction.
Multi-Modal Place Recognition (PR), addressing cross-modal scene retrieval, long-term localization, and
robust loop closure in challenging real-world scenarios.
News
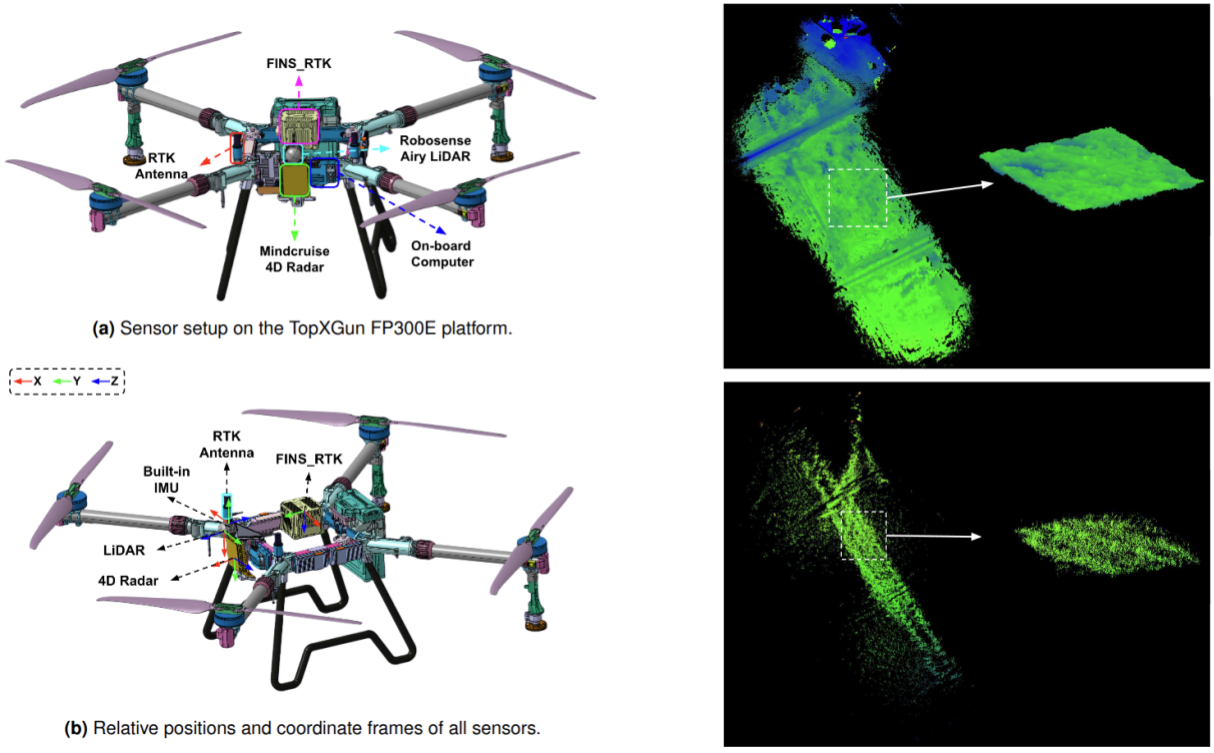
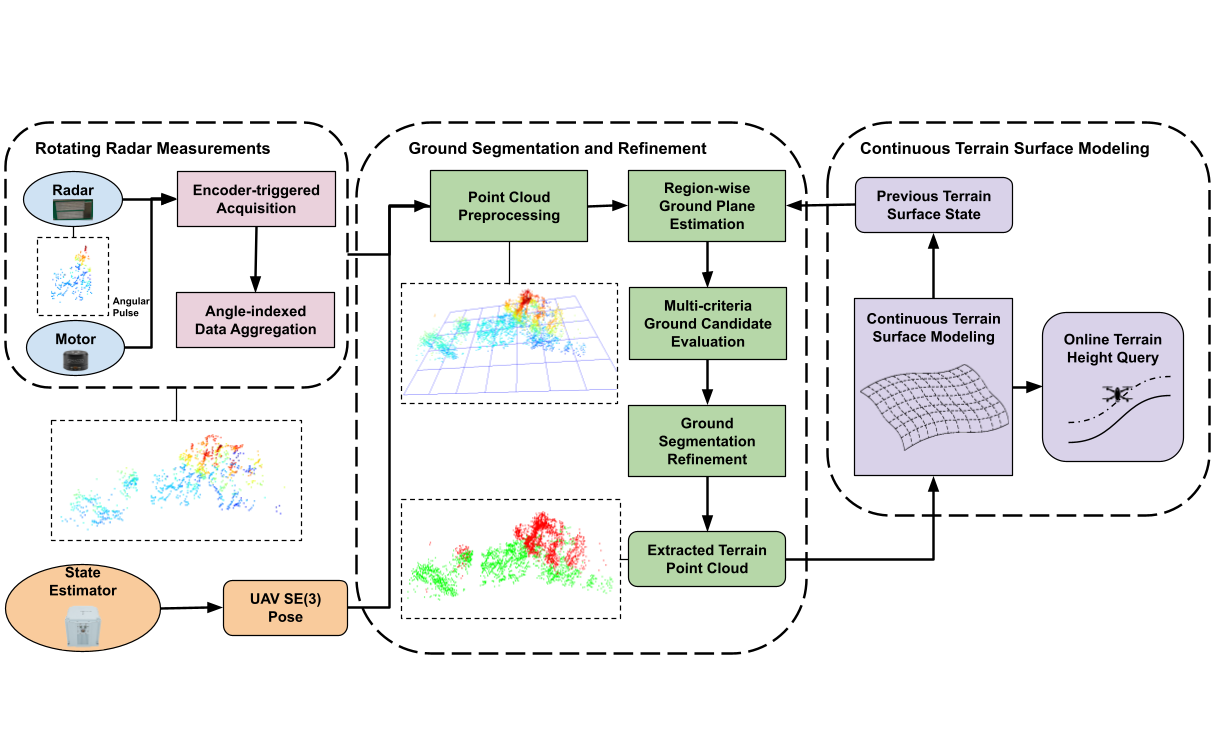
[Oct, 2026] New paper on agricultural UAV terrain perception using rotating mmWave radar is accepted by
IEEE T-FR.
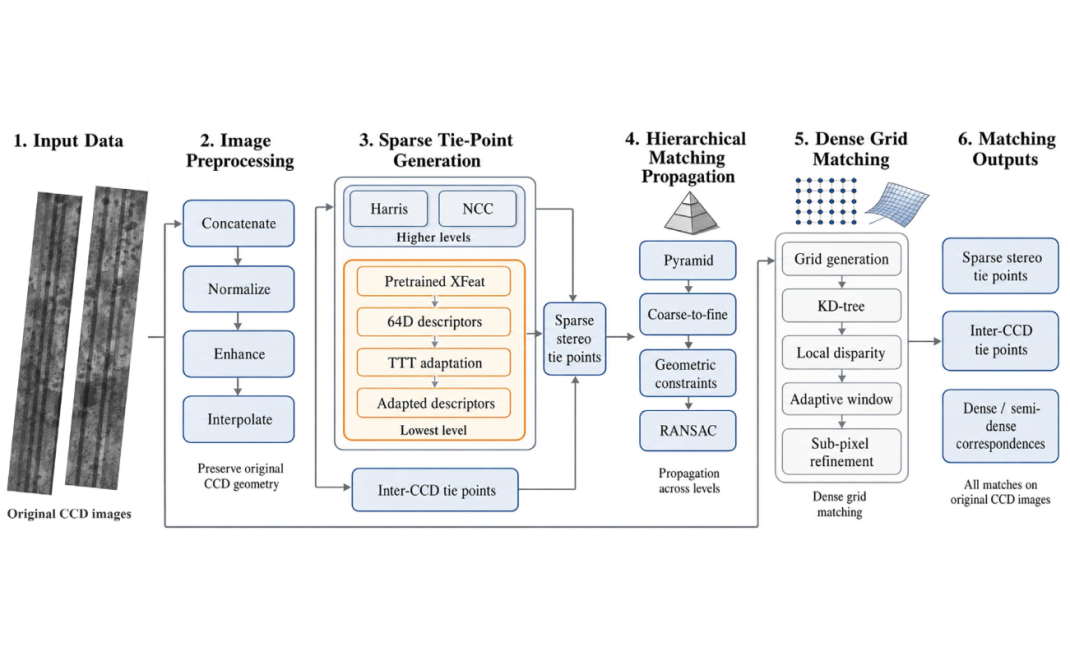
[Sep, 2026] New paper on bundle adjustment for Mars HiRISE multi-CCD stereo mapping is accepted by
ISPRS P&RS.
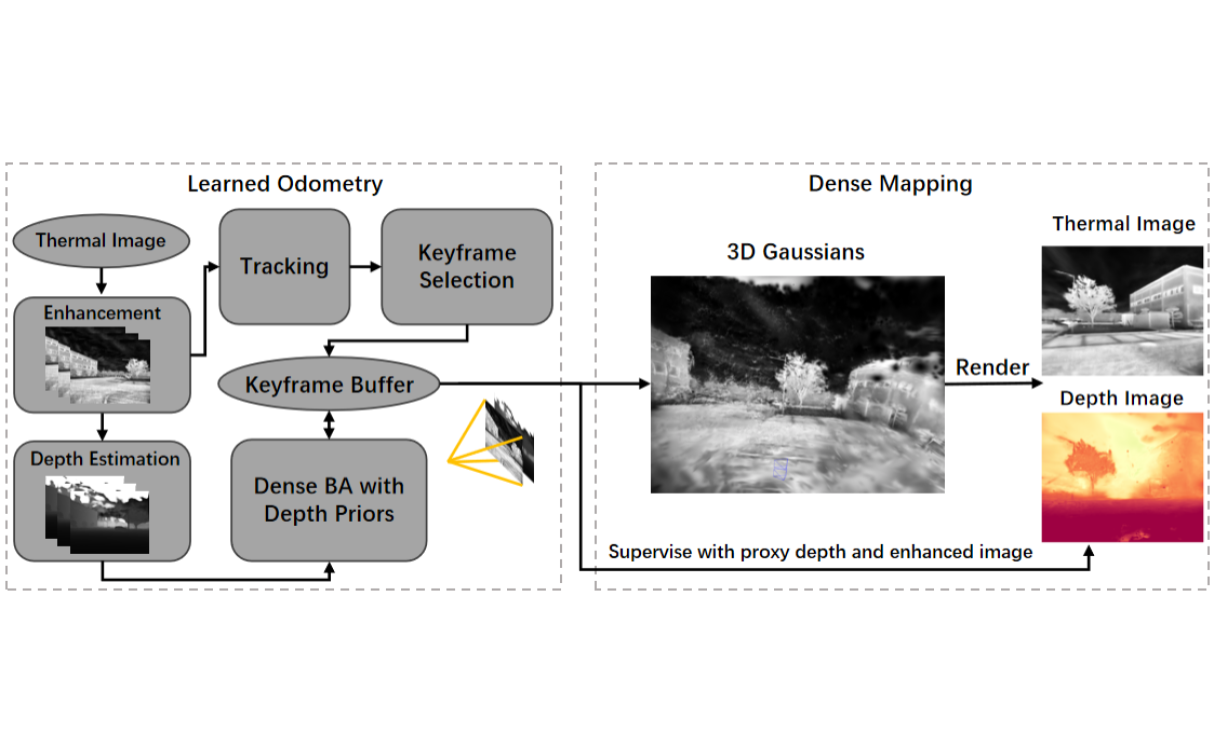
[Jun, 2026] New paper on robust thermal odometry and mapping using Gaussian Splatting is accepted by
IEEE/RSJ IROS 2026.
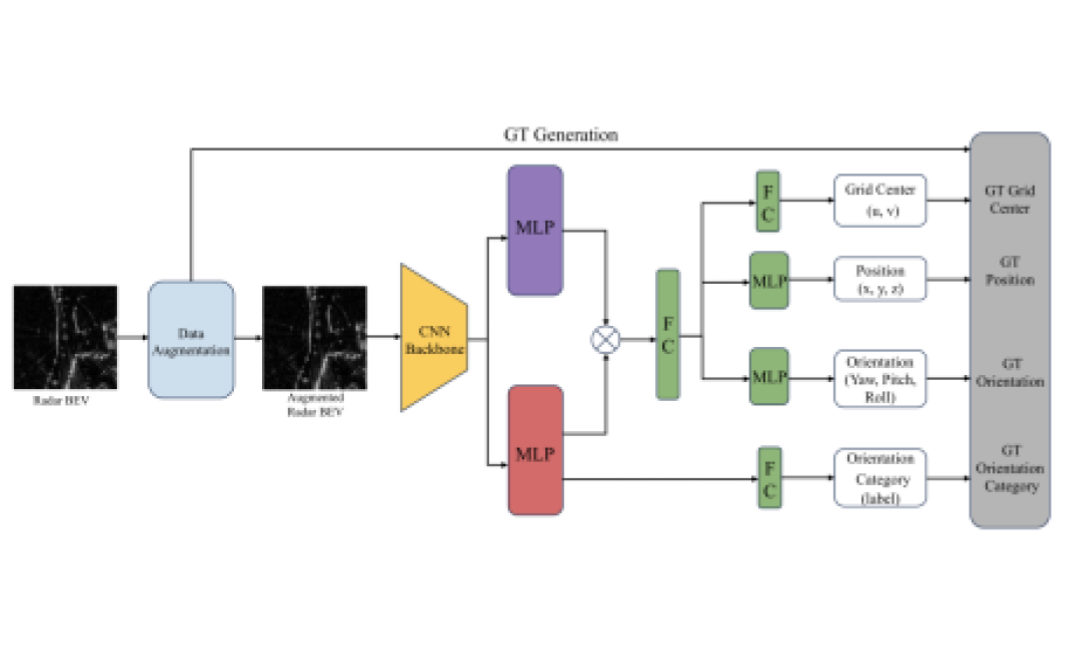
[Jun, 2026] New paper on deep radar BEV localization is accepted by BDAI 2026.
[Jun, 2026] New paper on high-quality orthoimage generation using 2D Gaussian Splatting is accepted by
SIViP.
[Jun, 2025] New paper on diffusion-based video super-resolution is accepted by ICSPS
2025.
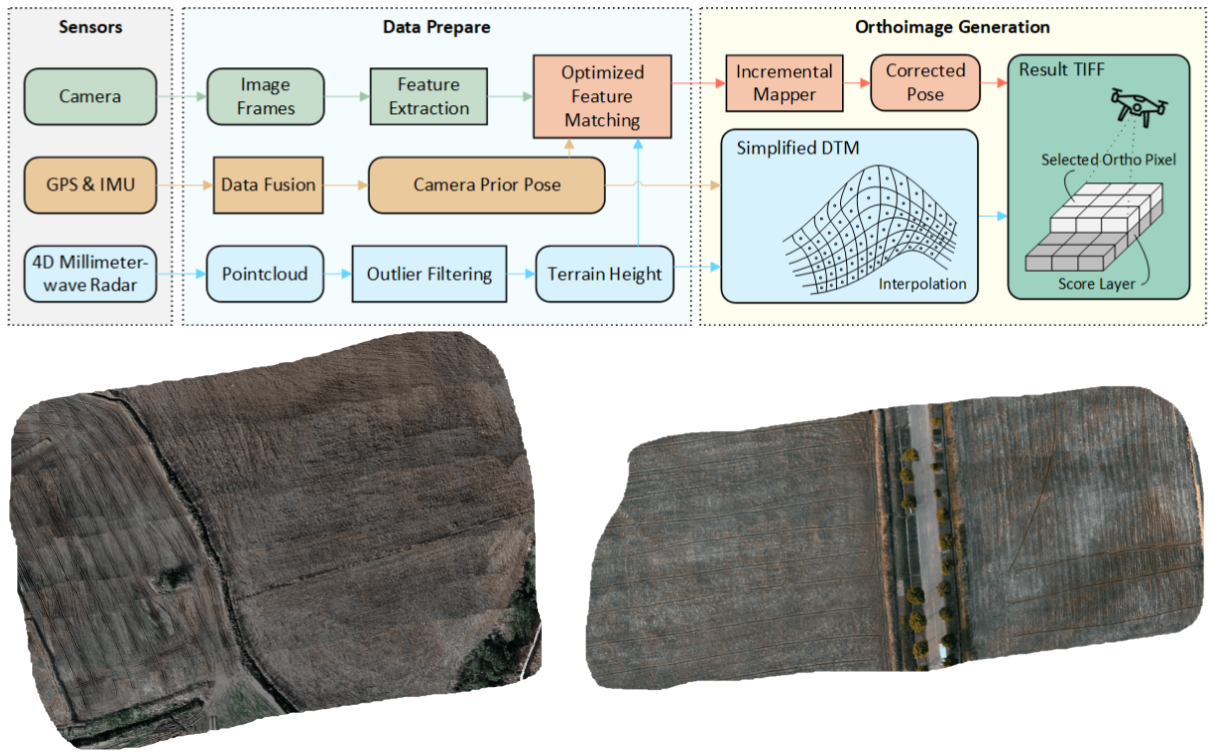
[Jun, 2025] New paper on rapid orthoimage generation using multi-sensor fusion is accepted by
IEEE/RSJ IROS 2025.
[May, 2025] New paper on image motion blur removal using video diffusion models is accepted by
IEEE ICIP 2025.